Our mission is to help physical AI learn from skilled human work.
A lab defines the task it needs to study. We’re developing a way for consenting workers to demonstrate that task and for a reviewer to show exactly what happened in each clip.
Karachi first / Exploring Canada
Early-stage programs. Partnerships and field locations are being explored.
02 — What we’re buildingKarachi, Pakistan
Field partnerships
Two ways to shape a pilot in Karachi. Bring a collection brief or help define a task your team knows well.
01
PROPOSED PARTNER WORKFLOWPAKISTAN FIRST
From your brief to a reviewable package.
01 / DEFINEYour specTask + acceptance criteria02 / RECORDHuman demoRecord to your protocol03 / REVIEWReviewed handoffVideo + agreed review notes
Start with your task, recording protocol and acceptance criteria.
For data suppliers
Start with one Karachi workplace.
Tell us what you need workers to record. We propose finding and qualifying a local site, onboarding consenting workers on your capture setup, and reviewing a small first batch with your team. If the footage meets your quality and cost targets, we can plan the next site together.
Partnership exploration
02
WORKPLACE TYPESPAKISTAN FIRST
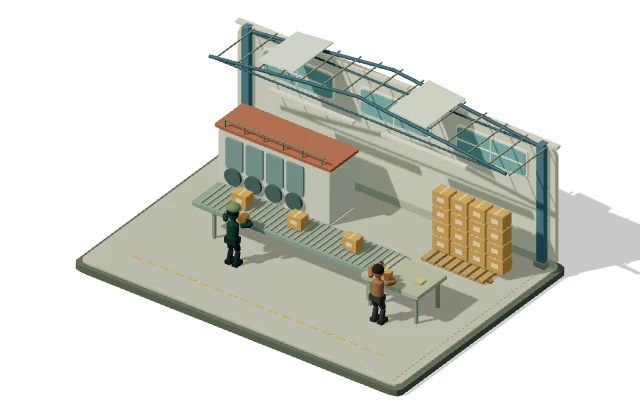
Packaging factories01 / 10
Pack · seal · prepare for dispatch
For workplaces & companies
Your workplace, seen by the people who run it.
We’re looking for Karachi businesses willing to explore recording a routine task safely, with workplace permission and worker consent.
Your worker records their day
In the proposed pilot, your business could sign up to receive a recording device on loan. Workers who opt in could be paid by the minute for recording agreed tasks. We would confirm device availability, the rate and which minutes qualify before anyone signs up.
10 workplace partner types we’re seeking · Select to explore
Pakistan first · Pilot exploration
03 — Research & developmentTools for first-person data
MotionOrigin Research
Explore two research prototypes and a simulated tomato-sorting study.
Egocentric generation
Egocentric VLM episode generator.
A model in development for generating egocentric task episodes and synthetic datasets for physical AI. Explore an annotated visual review of a planting episode.
Seedling placement
Visual quality
AI slop detector & annotator.
A custom model in development to flag visual inconsistencies and support human review of synthetic video. The examples follow a carton turn and a three-pot planting task.
A useful pilot starts with a clear question, an agreed protocol and a way to test the result.
Agree what useful looks like.
Define the task, required observations, permitted tools, variation and acceptance criteria before a recording program begins.
See what a first pilot looks like
Example: One packaging site in Karachi records workers packing cartons from their own point of view. Together we agree how many clips to try, what must be visible, and who can approve and access the footage.
What you review: A small batch of clips, notes on anything we rejected, and a recap of accepted footage and cost per accepted hour. Use that to decide whether to repeat or expand.
RGB video records visible activity. Measured force, tactile pressure and robot actions require appropriate sensors or robot-side data. Derived estimates need separate validation.
05 — Get in touchPilot inquiries
What task should your dataset capture?
Building a data program? Exploring a workplace partnership? Let’s define a useful first step.